I need a small CNC controller for desktop robots and machine tools. Thus I decided to try LinuxCNC with Raspberry Pi and MESA 7i90HD. I have Raspberry Pi 2, and Pi 3 has been ordered recently from aliexpress.
Surprisingly (or not so much) there's no clear manual how to install LinuxCNC on a Raspberry Pi. A lot of information is available, but in very different places (a debt to collect). I'll try to get everything together here.
Wednesday, March 1, 2017

Wednesday, August 7, 2013
Delta robot photos
Yesterday I took some photos with the details.
 |
| Platform |
 |
| Platform joints |
 |
| Actuator and home sensor |
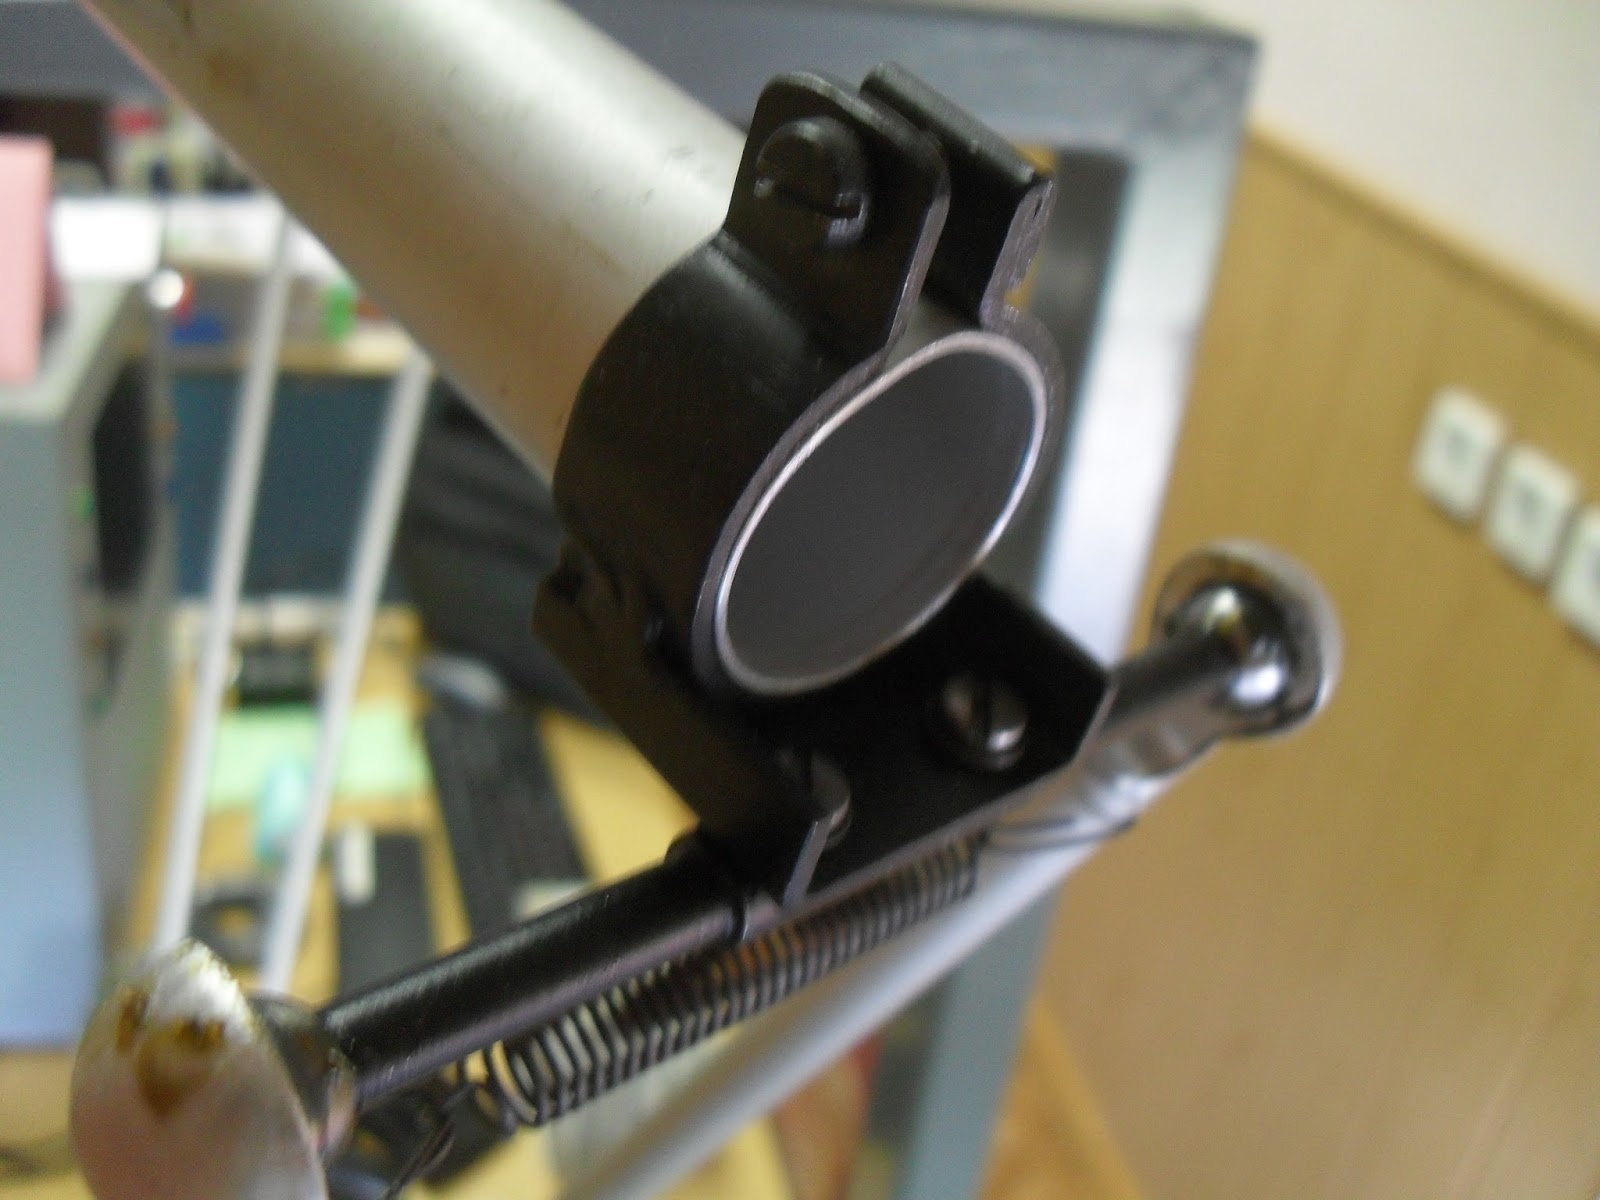 |
| Upper joints |
Monday, July 1, 2013
LinuxCNC delta robot
I considered building a delta robot for a long time. It's well known, but I was interested how rotary actuators work and how fast the robot can actually move. The main problem is rotary actuators stiff enough with high torque.
Recently I had a chance to purchase a few small harmonic reducers size 14 with 50W Yaskawa servo motors for a decent price. The reducers have cross roller bearing incorporated, so I just needed to install the reducers to the plate and screw the robot arms to their output plates. Robot arms and parallelograms were made of light aluminium tubes. The joints consist of steel balls and aluminium sockets.
Delta robot control is definitely a job for LinuxCNC. I used MESA 7i43 and 7i48 boards to control Yaskawa SGDH-A5 servo drives in analog velocity mode. Tuning PID and servo drives setting is the most difficult part. It's hard to get oscillation-free positioning with high acceleration. S-curve acceleration would be extremely useful for delta robots, but LinuxCNC does not support it (yet, I hope).
More photos and videos coming.
Saturday, June 8, 2013
Parasolid model for hexapod

I've made a Parasolid model as promised. It seems to open correctly in SolidEdge and SolidWorks. The model is pretty exact, though it might be different from actual machine in a few small details. Hope it can be useful for someone.
Sunday, March 3, 2013
CAD model for hexapod is coming
People keep asking me about CAD model for the hexapod machine. I'm working on it. Parasolid x_t format, I guess.
Wednesday, September 26, 2012
Yet another video of hexapod (must be the last)
Video with hexapod parallel robot 6 axis rapid moves from summer 2011. Way faster than the first video, but still not enough. Could be faster with better PSU for DMM servos, or with more advanced and more powerful servos. By the way, DMM already has Dyn-3 servos more suitable for closed loop, pity that it's too late for the hexapod.
Done (or almost done) with this machine, I'll probably cut one more final complete video and that's all.
But new machines and robots coming soon.
Done (or almost done) with this machine, I'll probably cut one more final complete video and that's all.
But new machines and robots coming soon.
Sunday, September 9, 2012
Fastest 2 dof parallel manipulator
Just when I was thinking what can be done with 2 rotary actuators and came up with SCARA and RRRRR robots.
Very nice robot, 0.1mm accuracy with 15 to 25g! And the main drawback of parallel robots - their small workspace - is fully defeated here. Though the control must be complicated, as it has 4 working modes.
Industrial grade robot, some ABB or Adept company should make it.
Very nice robot, 0.1mm accuracy with 15 to 25g! And the main drawback of parallel robots - their small workspace - is fully defeated here. Though the control must be complicated, as it has 4 working modes.
Industrial grade robot, some ABB or Adept company should make it.
Saturday, September 8, 2012
Another video of hexapod
I just found a video of hexapod parallel robot milling wood 5 axis from summer 2011, with improved velocity and acceleration. It should be MESA 7i43 that increased the step rate. And LinuxCNC is much more stable with hardware stepper than software.
The acceleration must be near 10m/s2, max velocity 10-12m/min.
Update: config files for 7i43 hexapod7i43.ini and hexapod7i43.hal.
The acceleration must be near 10m/s2, max velocity 10-12m/min.
Update: config files for 7i43 hexapod7i43.ini and hexapod7i43.hal.
Monday, April 9, 2012
LinuxCNC hexapod machine tool
As I promised, here's a bit more. Since EMC2 name has changed recently, now the machine becomes LinuxCNC hexapod.
The machine was assembled without ballscrews, servo drives connected to breakout boards and motors, and proved to rotate. Then the ballscrews were connected to the platform joints, and the nuts bolted to the actuators. Till the last moment there were doubts, that the platform would be rigid enough. But it proved rigid as planned! The very first moves were luckily captured on the video. Not much spectacular, but really exciting for me.
The machine was assembled without ballscrews, servo drives connected to breakout boards and motors, and proved to rotate. Then the ballscrews were connected to the platform joints, and the nuts bolted to the actuators. Till the last moment there were doubts, that the platform would be rigid enough. But it proved rigid as planned! The very first moves were luckily captured on the video. Not much spectacular, but really exciting for me.
Monday, July 11, 2011
CNC touch probes review
Looking for a simple inexpensive touch probe for parts measuring and hexapod calibration, during last two months I became a kind of market expert in touch probes. So, here's a summary of my investigations.
There are many top-quality industrial probes with 1um and better precision, based on kinematic, optical or strain gauge technologies. The most popular industrial probes are Renishaw.
Monday, May 16, 2011
Nice parallel robots from Hungary
Very nice homemade parallel robots by József Papp. All controlled by EMC2.
Hexapod
Thursday, April 14, 2011
EMC2 hexapod: the beginning
- prove the possibility to build 5 axis machine tool with decent performance out of cheap imprecise components;
- develop simple and effective desigh of joints and actuators for parallel machine tools;
- elaborate automated methods to calibrate parallel machine tool without expensive equipment.
Available information on existing multiaxis parallel machines was analysed and evaluated. The following considerations and requirements to parallel mechanism and its components were taken into account:
1. Single-type actuators for all dof to minimize the number of components. That leads to fully parallel machines only.
2. The simpliest possible design of all components to minimize manufacturing cost.
3. The lowest precision of base frame so that it could be weld and bolted with no additional equipment.
4. The servo motors preferred to steppers - they do not lose steps, have uniform torque up to maximum rotation speed.
5. The base frame should be tall enough to provide free access to working envelope and wide enough to be steady.
Wednesday, April 13, 2011
Foreword
I just did what I probably should have done some time ago - created blog about parallel machines. Here I'll try to post details on EMC2 hexapod being built right now, and probably some ideas, plans, interesting links etc. Comments and opinions are welcome. If you're interested, subscribe to this blog.
English is not my native language, so please be tolerant to possible mistakes.
English is not my native language, so please be tolerant to possible mistakes.
Subscribe to:
Posts (Atom)